Internship · Conpleks Innovation · Aug 2016 - Jan 2017
Autonomous robots at Conpleks
During my internship at Conpleks I worked on software for autonomous, GPS-guided robots. After a short introduction on Turf Tank One, most of my time went to a robot that picks up golf balls, where I wrote drivers, integrated the warning light, developed laser docking and tested in the field.
The internship
From August 2016 to January 2017 I was a software intern at Conpleks Innovation, a company that develops autonomous mobile robots. I started with a short introduction on Turf Tank One and was then put mainly on the golf ball robot.
Turf Tank One
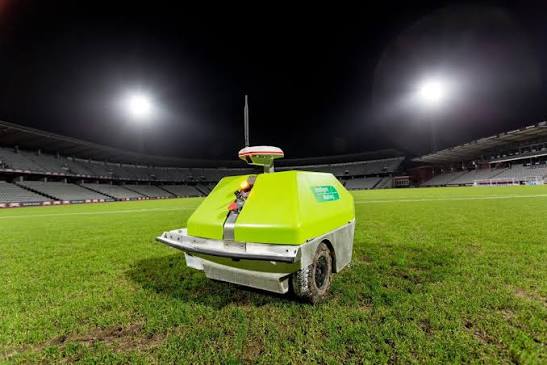
Turf Tank One is an autonomous robot that marks lines on sports fields, such as football pitches, using GPS. The pitch is planned and the marking is started from a tablet. It was my introduction to the robots before I moved on to the golf ball robot.
The golf ball robot
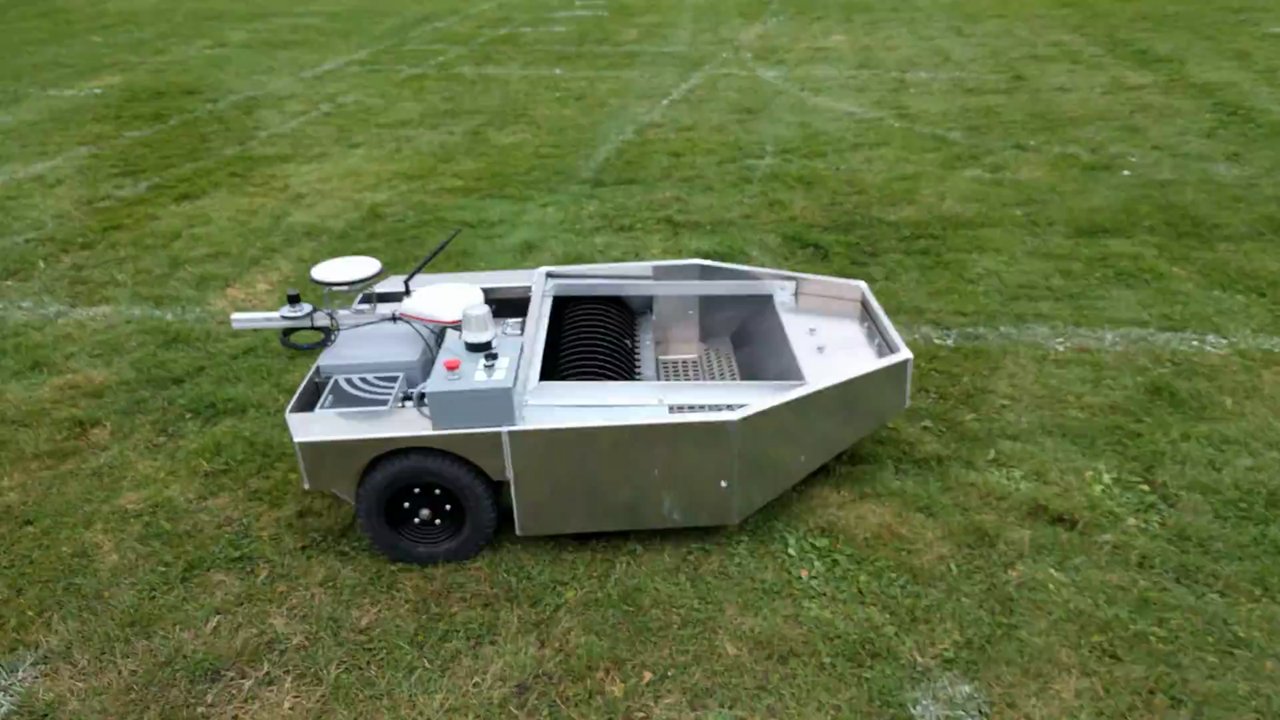
Most of the internship went to an autonomous aluminium robot that picks up golf balls. The picker is an ordinary golf ball picker built into the robot. The robot has GPS, a control box with an emergency stop and a warning light. It does not search for the balls. It drives a fixed pattern over the area while the picker collects them along the way.
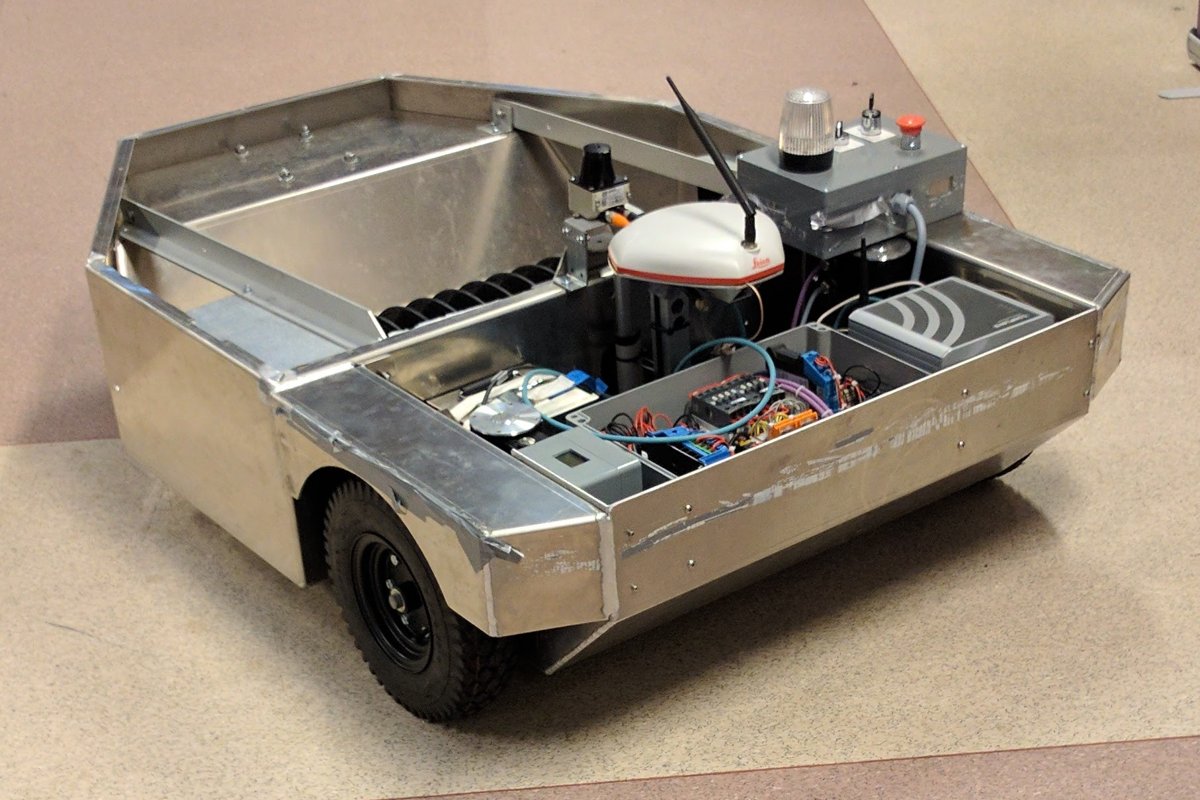
My contribution was software in the ROS framework, covering four things:
- Drivers: drivers for the robot.
- The warning light: development and integration of the light into the robot.
- GPS: a smaller part of the work on the driver for the robot’s u-blox GPS receiver.
- Laser docking: an algorithm for docking with laser alignment. It was the hardest task of the internship.
Testing in the field
Field testing was the most fun part of the internship, and I handled a large share of it. The robots were tested on both grass and paved ground, and that is where you see how GPS, weather, ground and mechanics work together. The faults that do not show up at a desk show up there.